Built independently by an author, for readers. Read the story and support ChapterPal

keyword

object recall

Object recall is an evaluation metric in computer vision that measures the fraction of actual, ground-truth objects within an image or dataset that an object detection model successfully localizes and identifies. It is calculated as the ratio of true positive detections—where a predicted bounding box sufficiently overlaps a target object according to a specified Intersection over Union threshold—to the total number of real objects present. By measuring how effectively a model avoids missing targets, object recall reflects the completeness and sensitivity of object proposal generation and detection pipelines. In advanced paradigms such as open-world object detection, this metric is often subdivided to assess how comprehensively a system can detect both previously learned categories and novel or unknown instances that appear without explicit training labels.

1 item

PROB: Probabilistic Objectness for Open World Object Detection

PROB: Probabilistic Objectness for Open World Object Detection

Orr Zohar, Kuan-Chieh Wang, Serena Yeung

OrganizationsStanford University

Why you should read this

Presents a probabilistic framework that models feature-space objectness distributions to distinguish unknown objects from background without pseudo-labels, doubling unknown object recall over prior open-world detection methods.

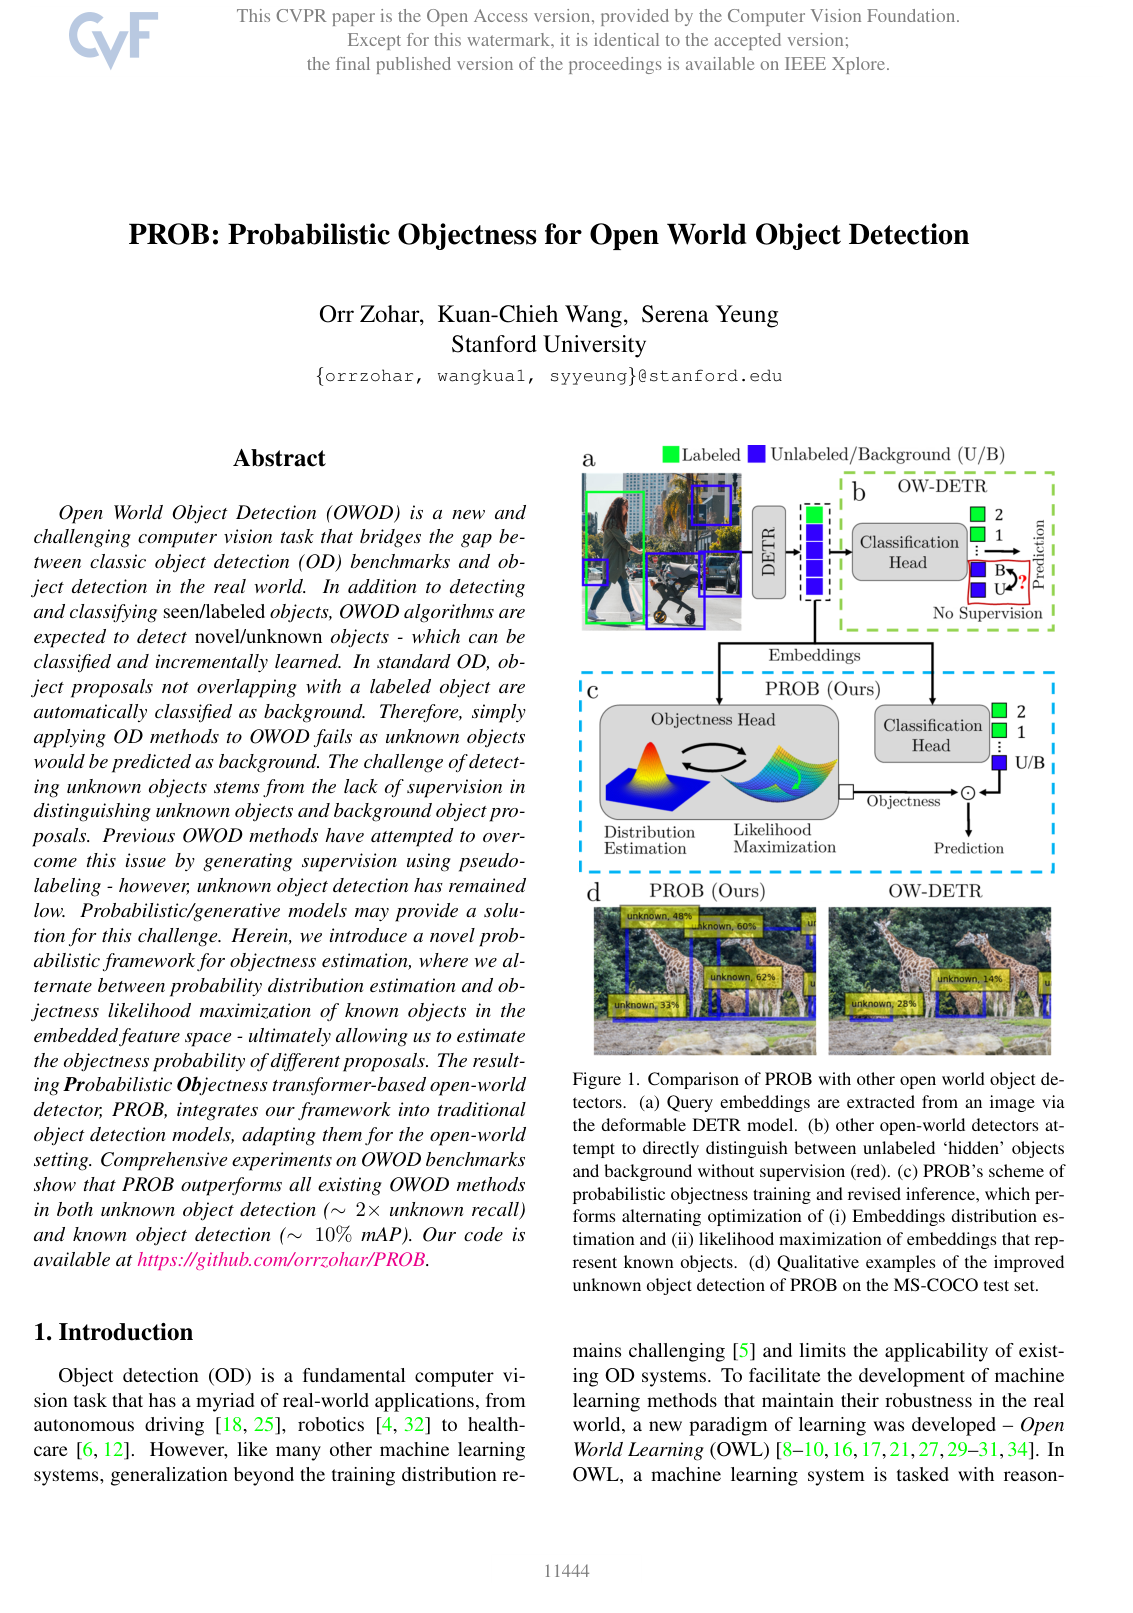
Open World Object Detection (OWOD) is a new and challenging computer vision task that bridges the gap between classic object detection (OD) benchmarks and object detection in the real world. In addition to detecting and classifying seen/labeled objects, OWOD algorithms are expected to detect novel/unknown objects - which can be classified and incrementally learned. In standard OD, object proposals not overlapping with a labeled object are automatically classified as background. Therefore, simply applying OD methods to OWOD fails as unknown objects would be predicted as background. The challenge of detecting unknown objects stems from the lack of supervision in distinguishing unknown objects and background object proposals. Previous OWOD methods have attempted to overcome this issue by generating supervision using pseudo-labeling - however, unknown object detection has remained low. Probabilistic/generative models may provide a solution for this challenge. Herein, we introduce a novel probabilistic framework for objectness estimation, where we alternate between probability distribution estimation and objectness likelihood maximization of known objects in the embedded feature space - ultimately allowing us to estimate the objectness probability of different proposals. The resulting Probabilistic Objectness transformer-based open-world detector, PROB, integrates our framework into traditional object detection models, adapting them for the open-world setting. Comprehensive experiments on OWOD benchmarks show that PROB outperforms all existing OWOD methods in both unknown object detection (~ 2× unknown recall) and known object detection (~ 10% mAP). Our code is available at https://github.com/orrzohar/PROB.

Added

2026-09-26